NASA Robotic Mining Competition
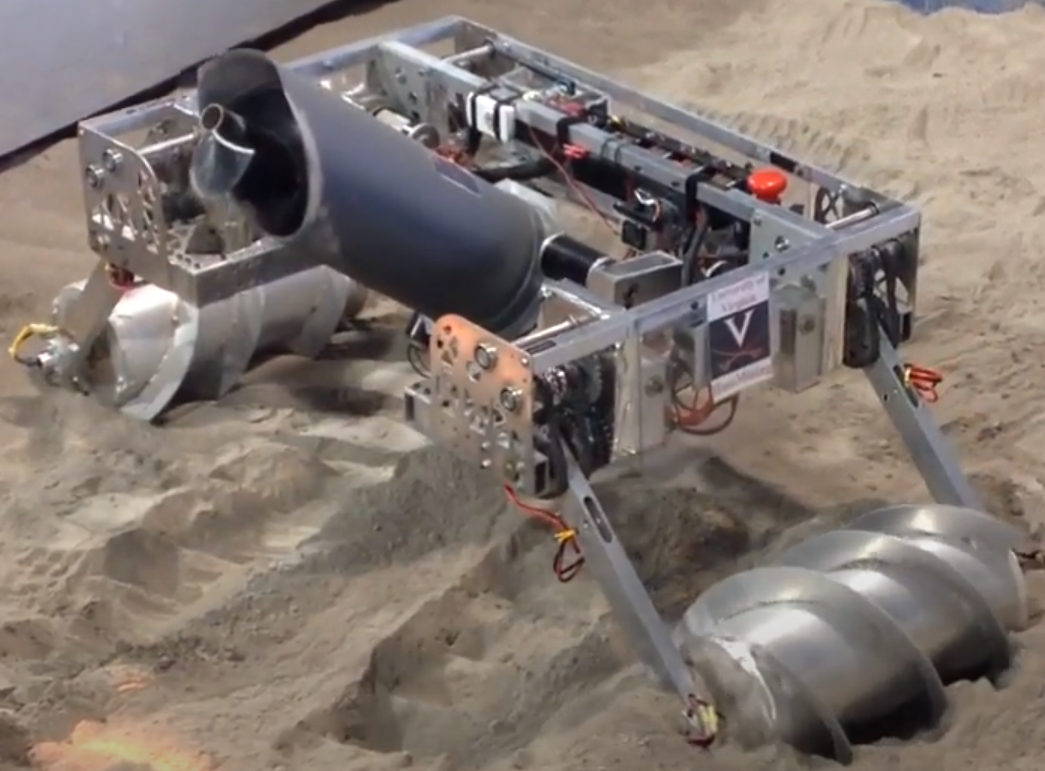
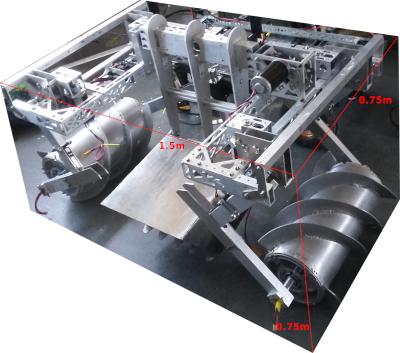
From 2013 to 2017, I founded and led the University of Virginia team in the NASA Robotic Mining Competition. Each year, a team of roughly 10–20 students (with a core group of about five) designed and built a custom, approximately 80 kg teleoperated robot to collect simulated Martian regolith.
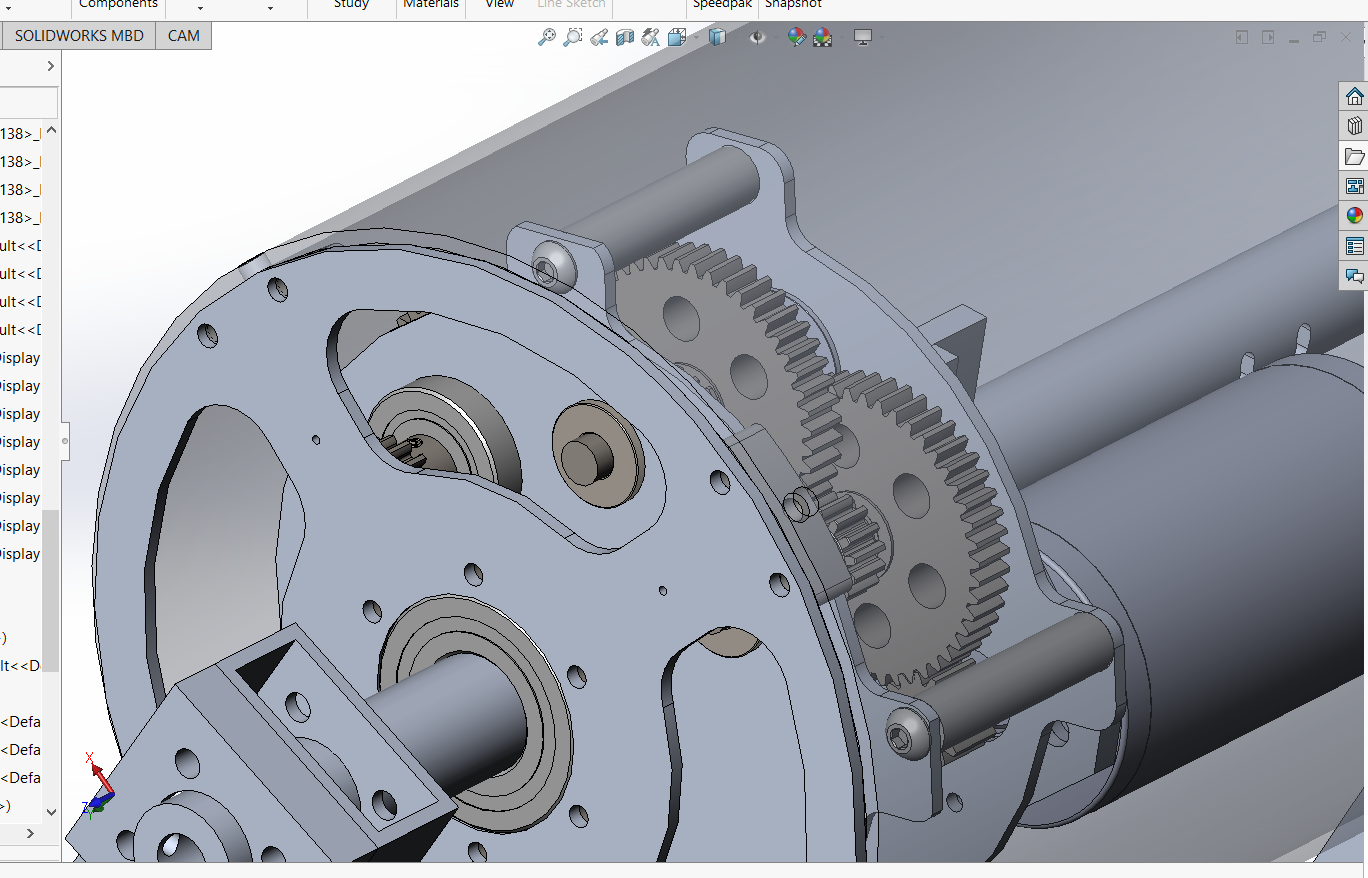
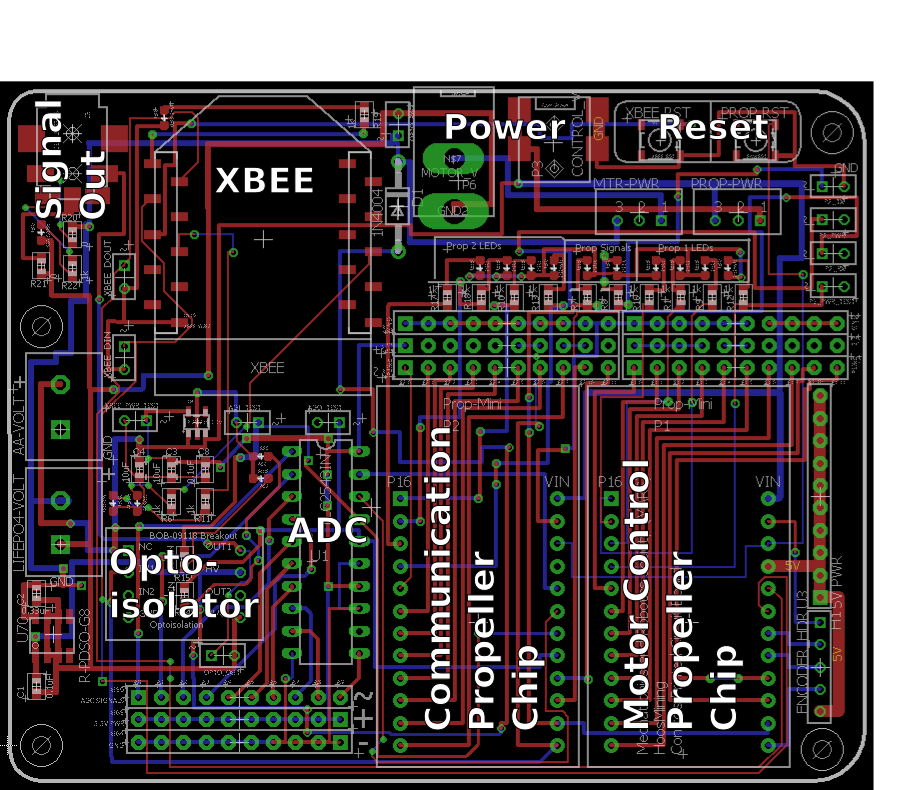
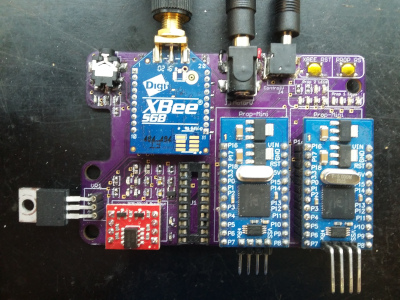
I designed and manufactured the screw-propulsion system and designed and built the controls PCB. I also wrote controls software, integrated and manufactured systems, and led project management and annual fundraising of $5K–$10K.
In 2016, the team received an Honorable Mention for Innovation. A competition video shows the 2016 teleoperated run. In 2017, the robot collected 11.4 kg of material in one 10-minute run.